γ0: A Generalist Policy for Multi-Embodiment Motion Control
We’re building a foundation motion policy for any robot, on the ground or in the air, with wheels, legs or rotors.
It learns across millions of embodiments derived from a growing collection of more than 200 realistic robot models. With every robot added, the policy becomes more capable and better able to transfer to new robots.
Contribute your robot and help us build the largest open-source robot collection for multi-embodiment training and deployment! ↓
Real-world deployments
A single policy controls every robot at the joint level.
Unitree Go2 · Silver Badger · Unitree G1
Unitree Go2 · Silver Badger · Unitree G1
Unitree H1
Training methodology
We take Unified Robot Morphology Architecture (URMA) and Embodiment Scaling Laws to the extreme by randomizing robot embodiments on the fly throughout training. This exposes a single policy, conditioned on each embodiment, to the broadest possible range of robot morphologies. By learning from this diversity, the policy develops generalizable motion skills that transfer to new embodiments.
Our robot collection
6 of 308 robots
 1X Neo
 Adam Lite
 Agibot A2
 AgiBot A3 T2.5
 Agibot D1
 Agibot G1
 Agibot X1
 Agibot X2
 Agilex Limo
 Agilex Piper
 Agility Digit
 Agiloped
 Aibo
 Airbus VISPA
 Aloha
 AM-Bench FA-Hexa
 AM-Bench Omni-Hexa
 AM-Bench UA-Hexa
 AM-Bench UA-Quad
 Anymal B
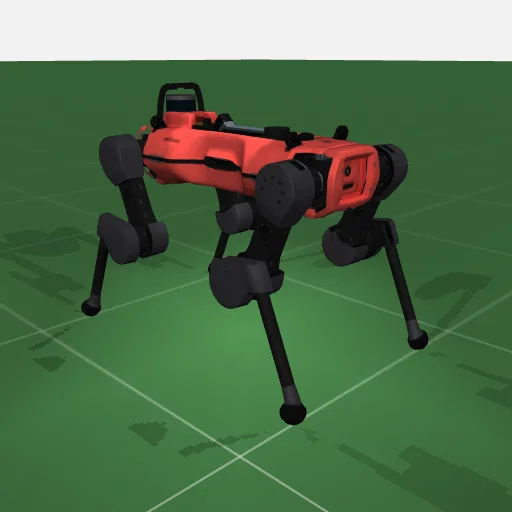 ANYmal D
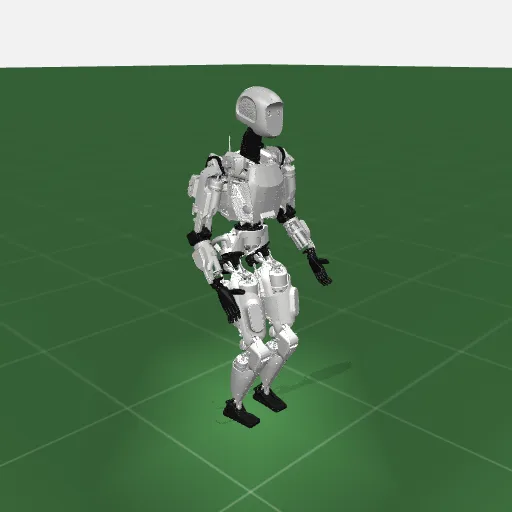 Apptronik Apollo
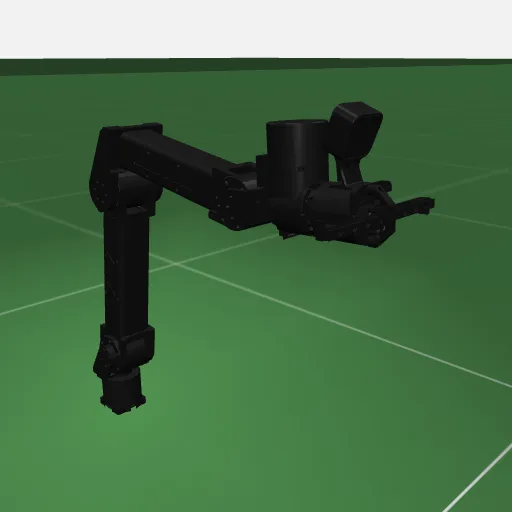 Arx L5
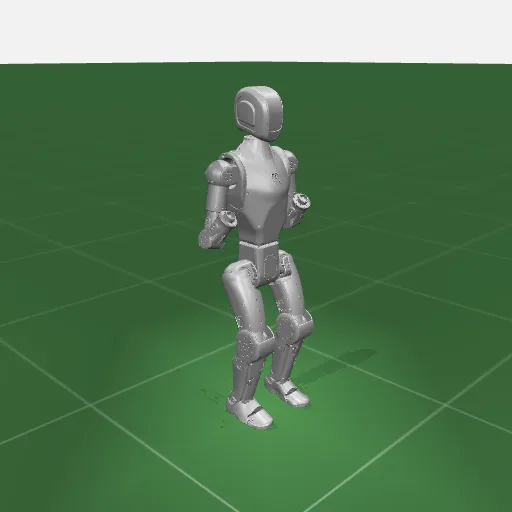 Asimov 1
 Asimov V0
 Atlas
 BamBot
 Barkour V0
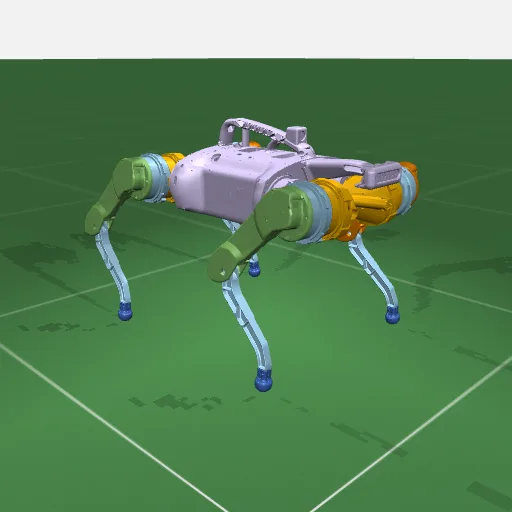 Barkour Vb
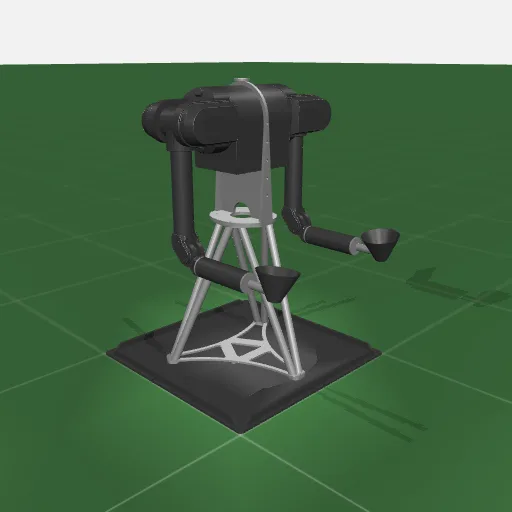 Barrett WAM Dual
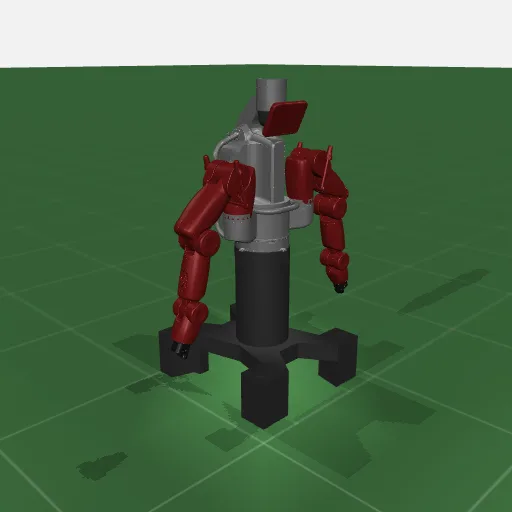 Baxter
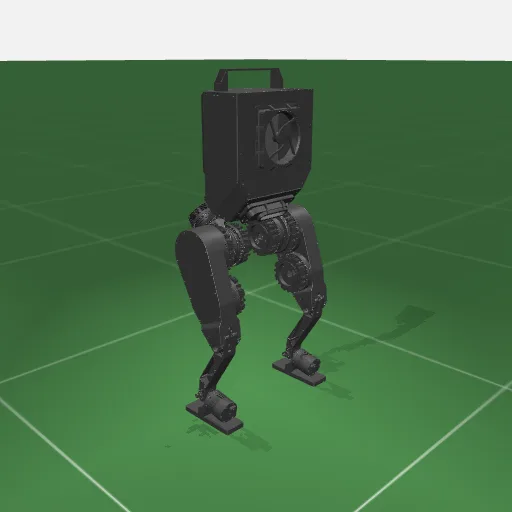 Berkeley Humanoid
 Berkeley Humanoid Lite
 Bittle
 BlueROV2 Heavy
 Bolt
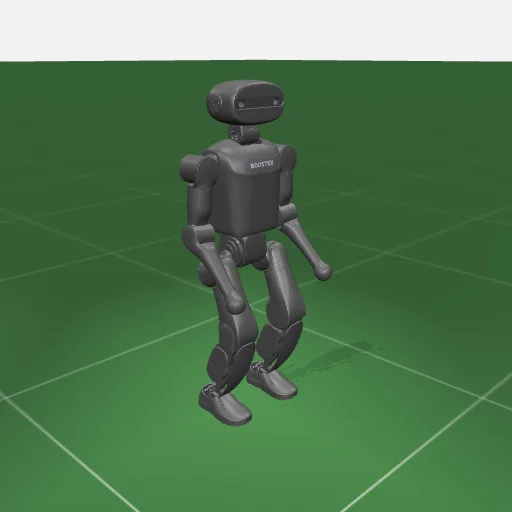 Booster K1
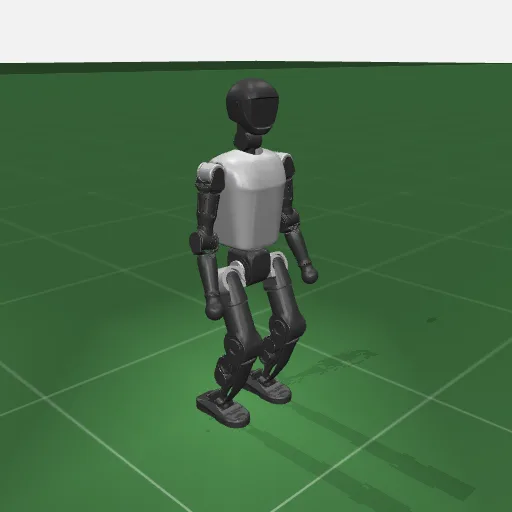 Booster T1
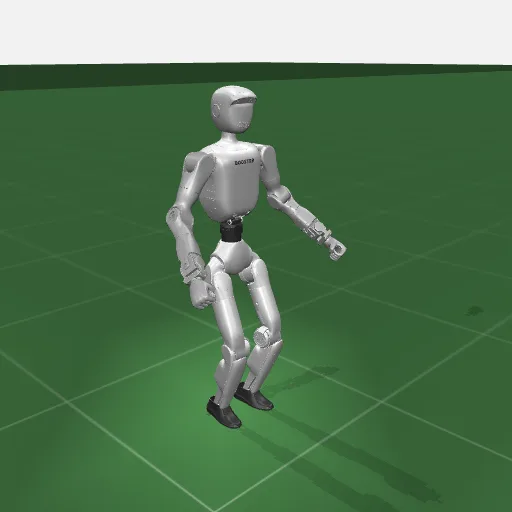 Booster T2
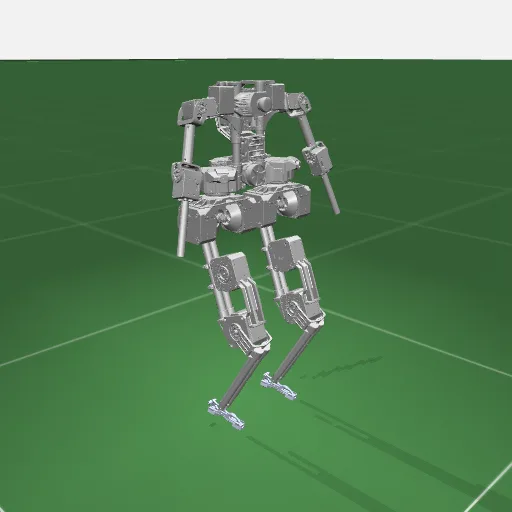 BRUCE
 Cassie
 CENTAURO
 Cerepal ANT001
 Clearpath Dingo
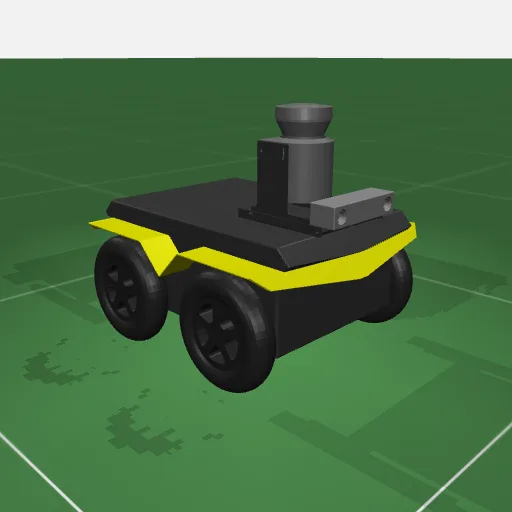 Clearpath Jackal
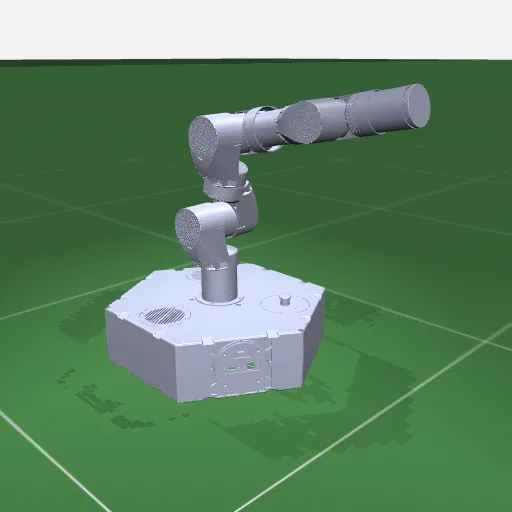 Comau e.DO
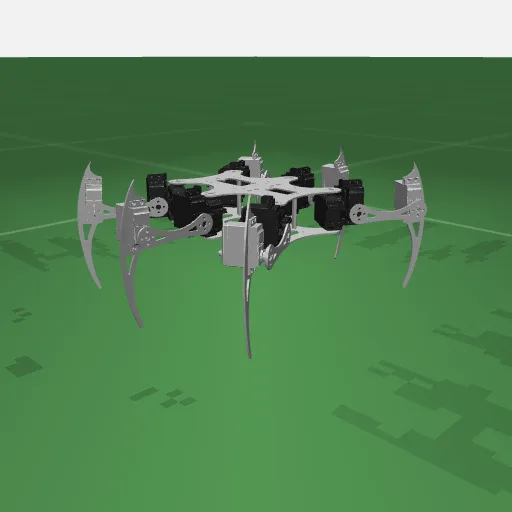 Crab
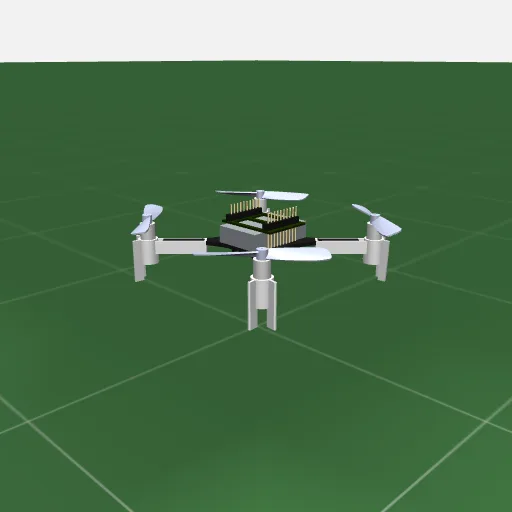 Crazyflie 2
 Cubic Doggo
 Custom Hexapod
 Cyberdog2
 cyclBot
 DDT Diablo
 Ddt Tita
 Deep Robotics DR02 Standard
 Deeprobotics Lite3
 Deeprobotics M20
 Deeprobotics X30
 Denso Cobotta
 Denso Cobotta 1300
 Dlr Toro
 Doosan H2017
 Draco3
 DroidUp E1
 Duck Mini
 Duke Humanoid
 Dynamixel 2r
 Elf2
 ENGINEAI PM01
 Engineai Sa01
 Ergocub
 Eve R3
 Evobot
 Fanuc Crx10
 Fanuc M-710iC
 Festo Cobot
 Fetch Panda
 Flexiv Rizon4
 Fourier Gr1t1
 Fourier Gr1T2
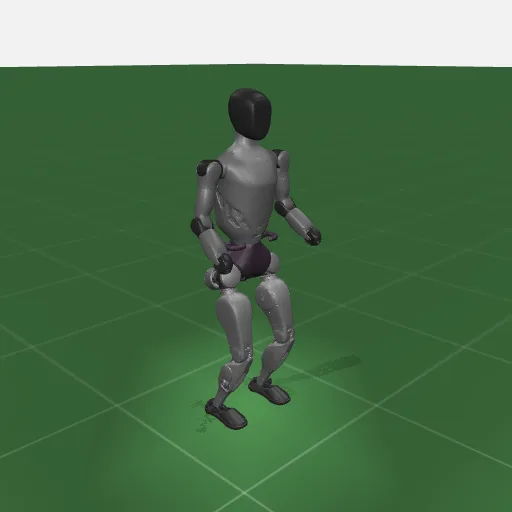 Fourier Gr2V3
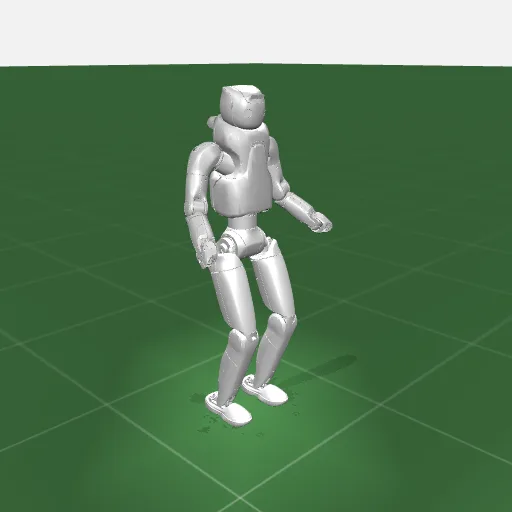 Fourier Gr3
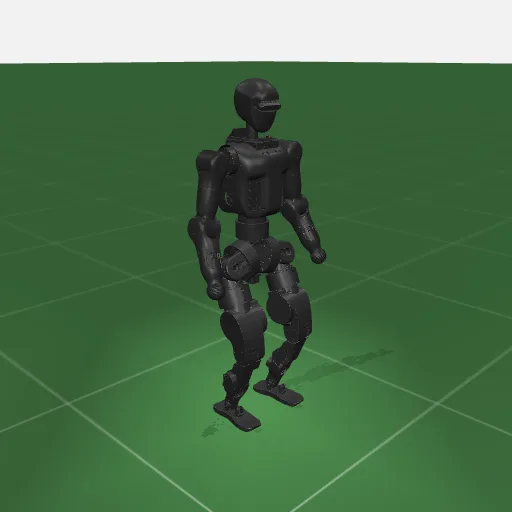 Fourier N1
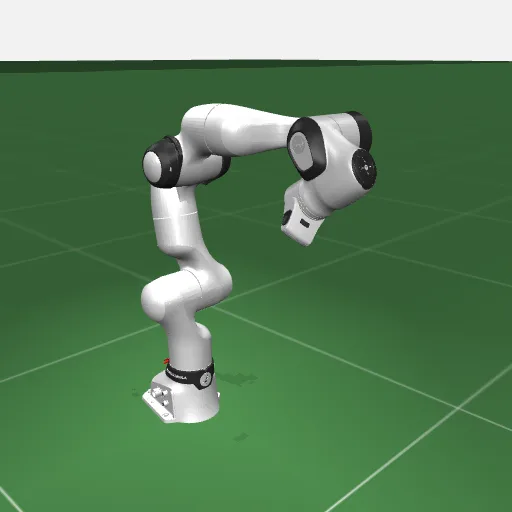 Franka Fr3
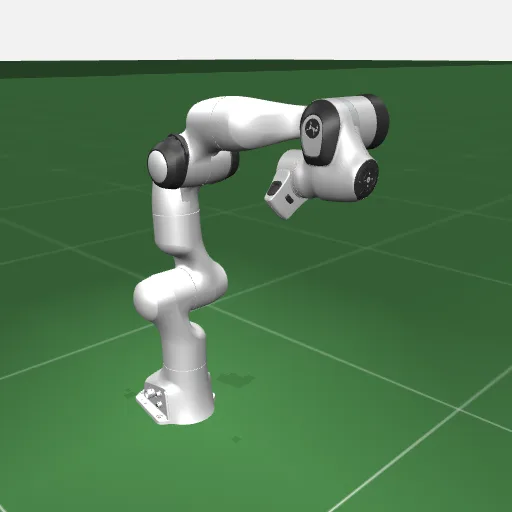 Franka Panda
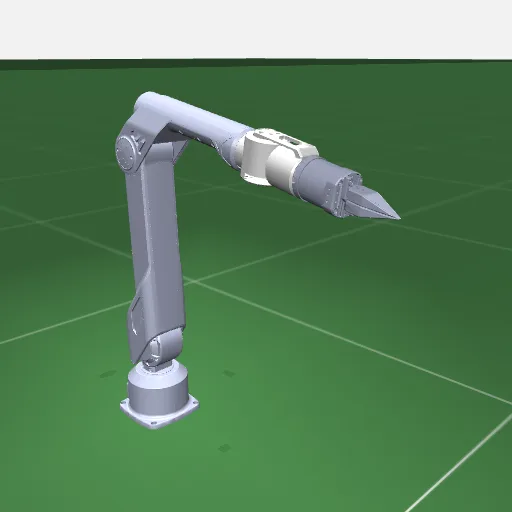 Galaxea A1
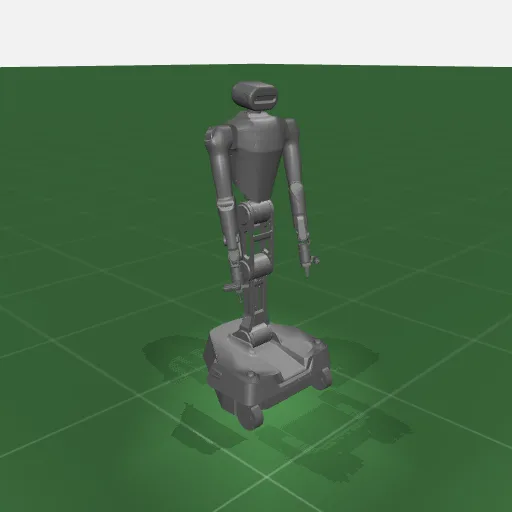 Galaxea R1 Pro
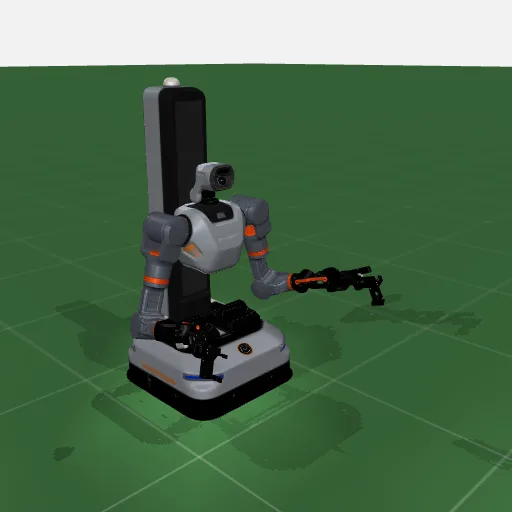 Galbot S1
 GENE.01
 Ggldnl Hexapod
 Ghost Minitaur
 Gimbalrotor tri_omni
 Ginger
 Golem
 Google Robot
 Green
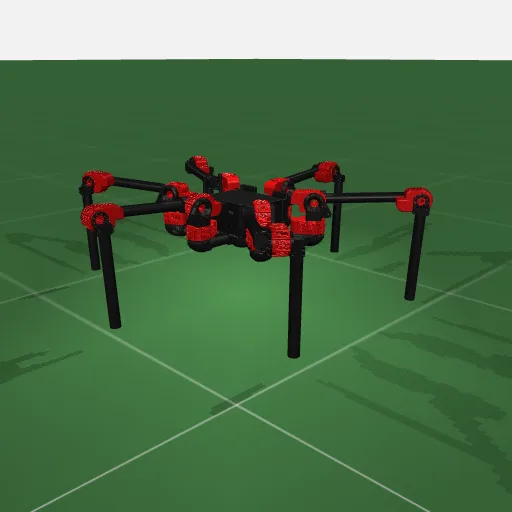 HEBI Daisy
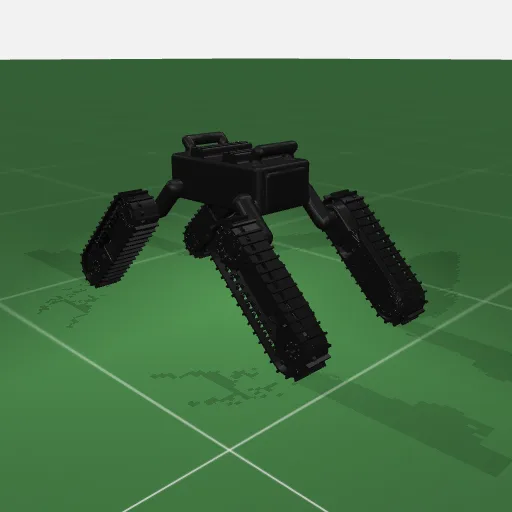 HEBI Tready
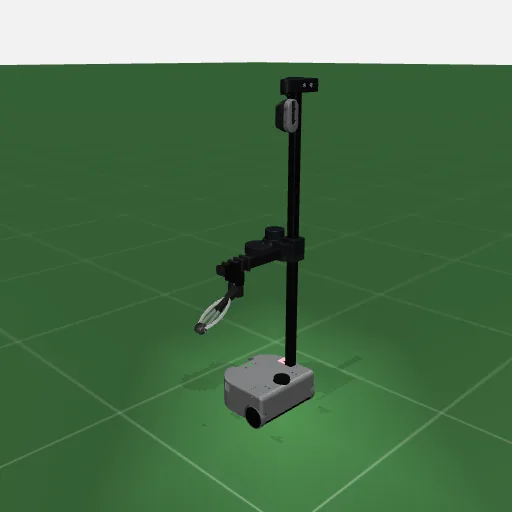 Hello Stretch
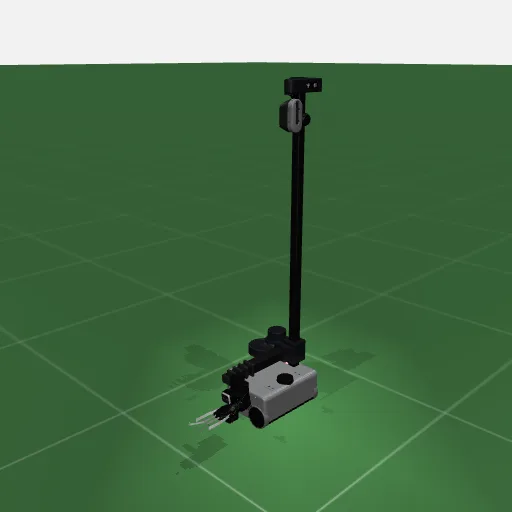 Hello Stretch 3
 Hello Stretch 4
 Hexbug
 Hightorque Pi Plus
 Honey Badger 40
 Honey Badger 50
 Honey Badger 50W
 Hsr
 Hunter Biped
 Husky A300
 Husky Dual UR5e
 Hyq
 HyQReal2
 I2rt Yam
 Icub
 Idealworks Iwhub
 IIT R1
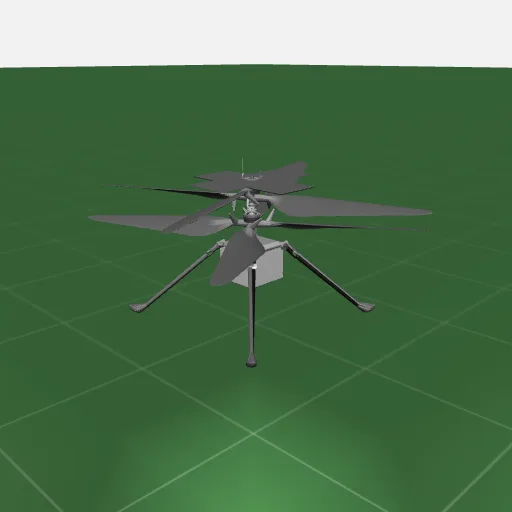 Ingenuity
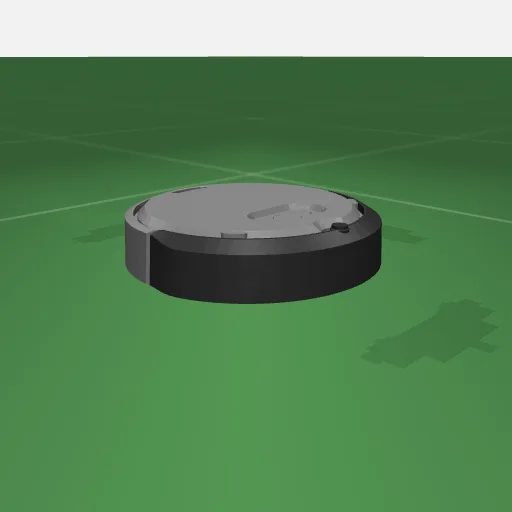 Irobot Create3
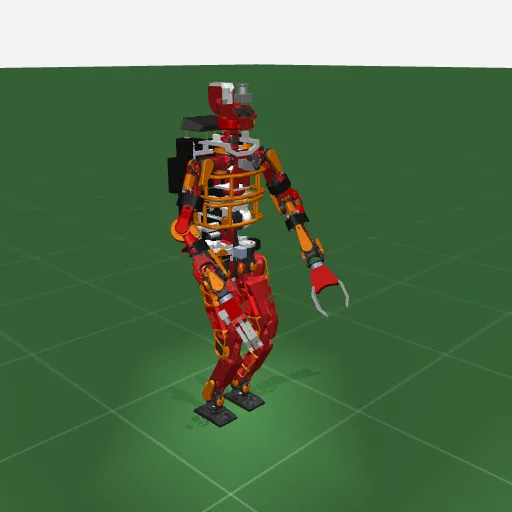 JAXON
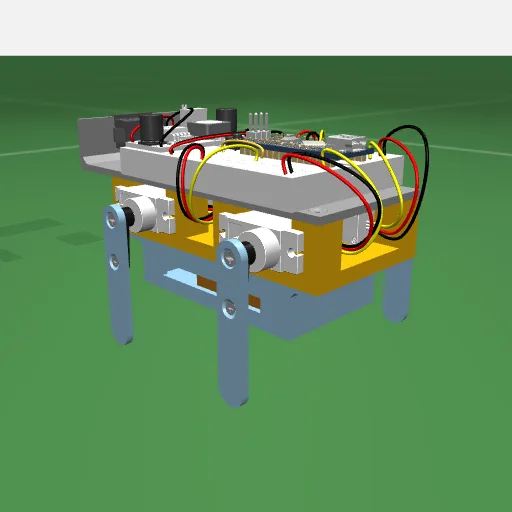 Jayli Four Legged
 JSK DRAGON
 Jvrc1
 Kangaroo
 Kawasaki Rs007n
 Kawasaki Rs013n
 Kawasaki Rs025n
 Kawasaki Rs080
 Kbot V1
 Kbot V2
 KHR-3HV
 KiLTRO
 Kingfisher
 Kinova Gen3
 Kinova Jaco2
 Koch V1 1
 Kolibri
 Kuavo S45
 Kuka Iiwa 14
 Kuka Kr210
 KYON
 Leo Rover
 LimX Luna
 Limx Oli
 LimX Tron1 WF
 LimX Tron2 DASF
 LimX Tron2 DASF2
 LimX Tron2 SF
 LimX Tron2 WF
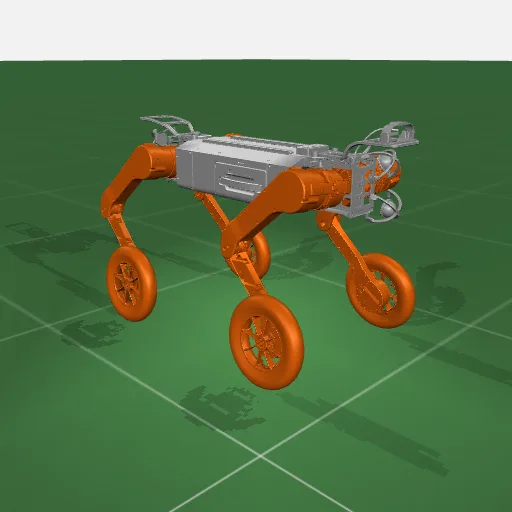 LimX WL P311E
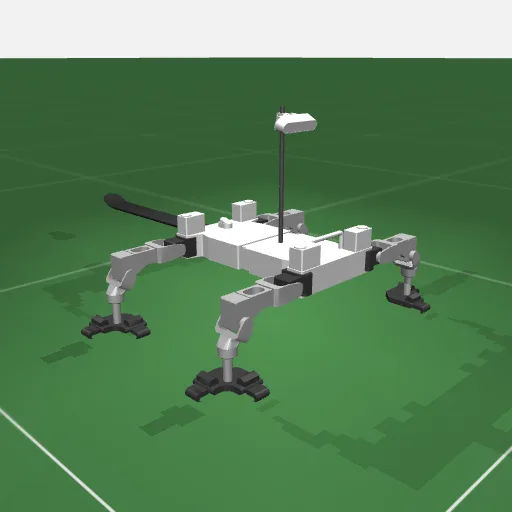 LORIS
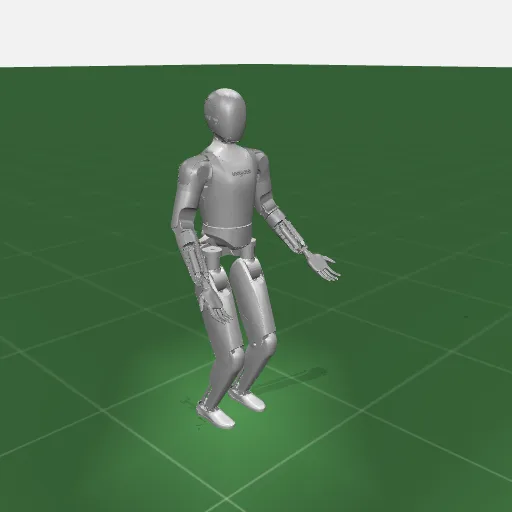 Magicbot Gen1
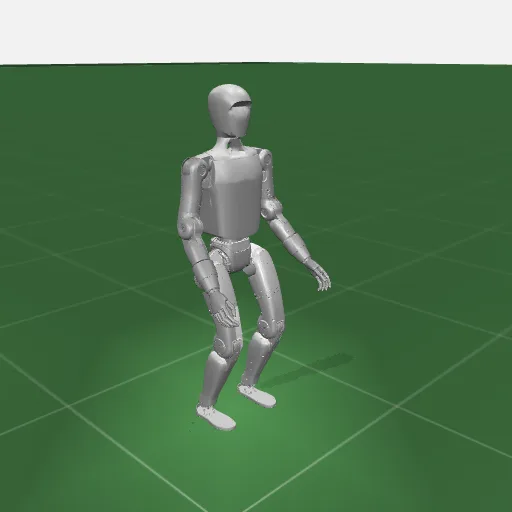 Magicbot Z1
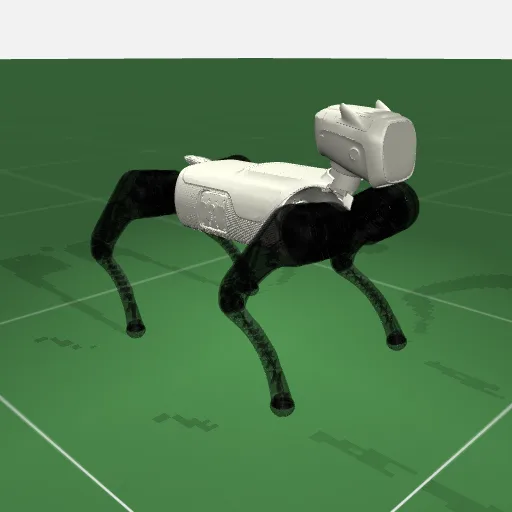 Magicdog
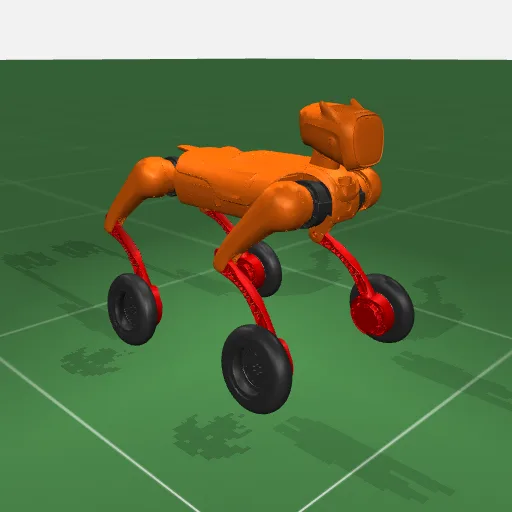 Magicdog W
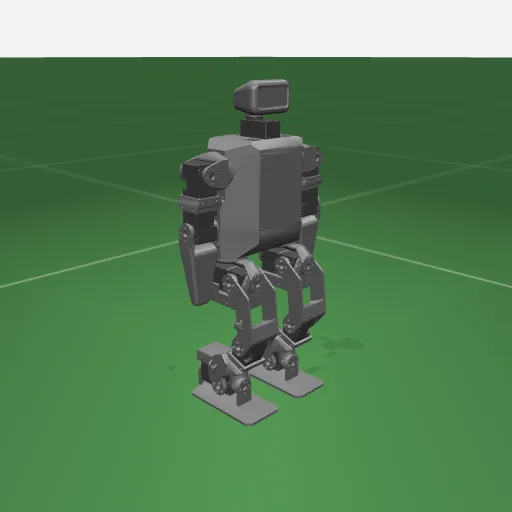 Microban
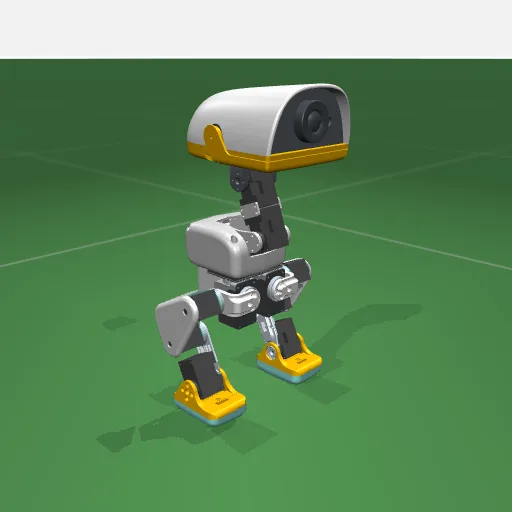 Microduck
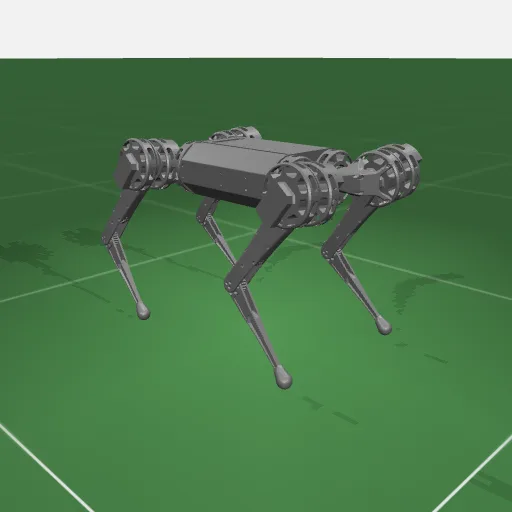 Mini Cheetah
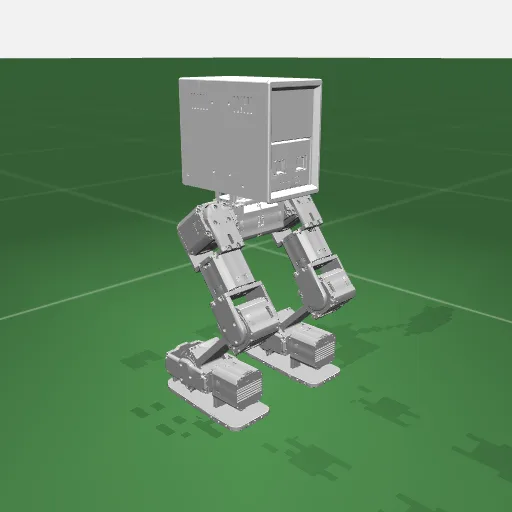 Mini Pi
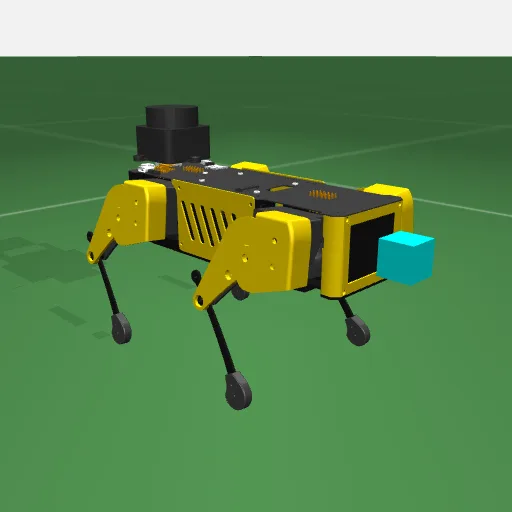 Mini Pupper
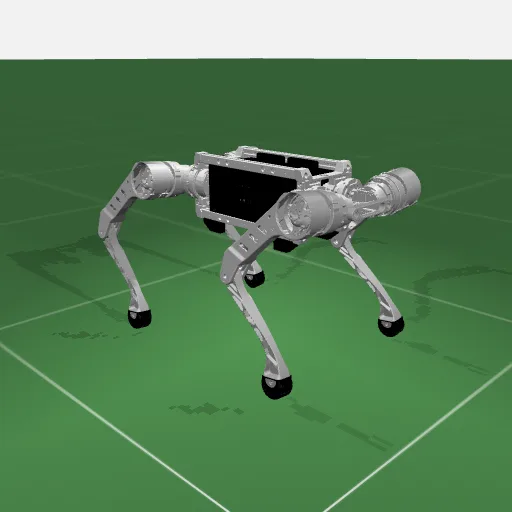 MirrorMe BPX
 Mit Humanoid
 Motoman Nex10
 Nao V5
 Nextage
 NimbRo OP2X Adult
 Noetix E1
 Noetix N2
 North POC2
 Northwestern Humanoid
 Nova Carter
 Nvidia Kaya
 OLYMPUS
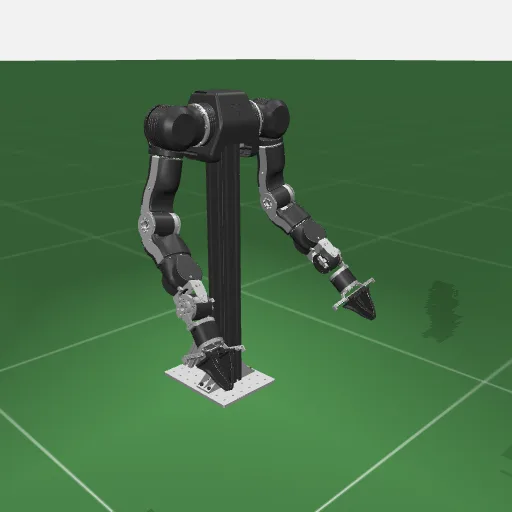 Openarm
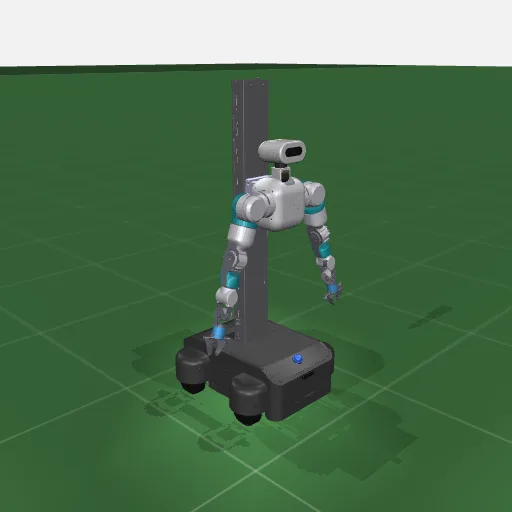 OpenFleX
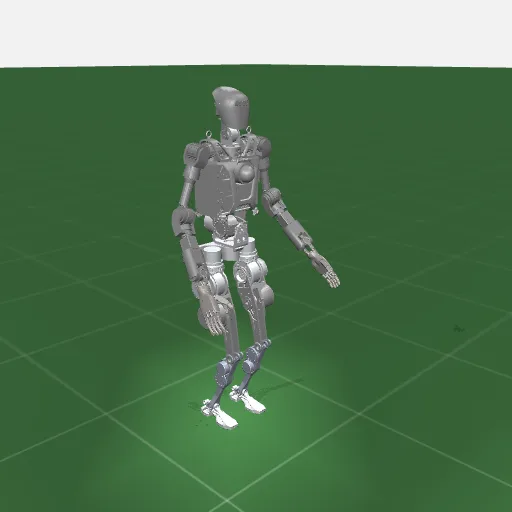 Openloong
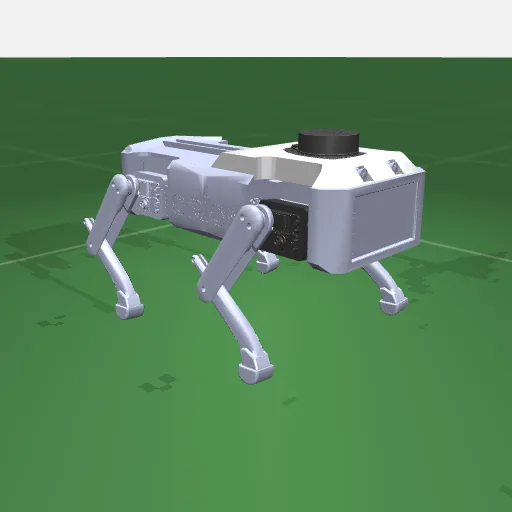 Orion
 P0
 PAMY2
 PAWS
 Pepper
 PINGU
 Pleurobot
 Poppy Ergo Jr
 Poppy Humanoid
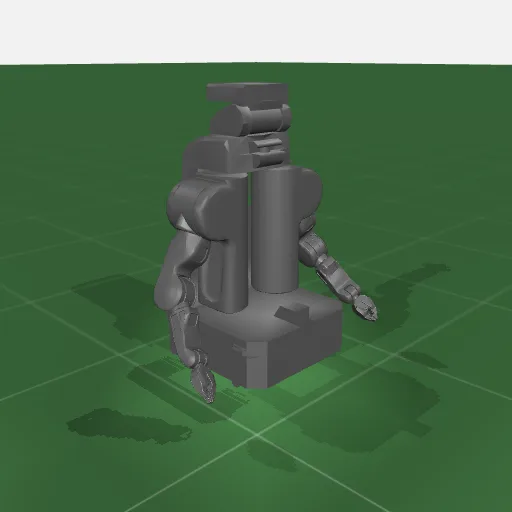 Pr2
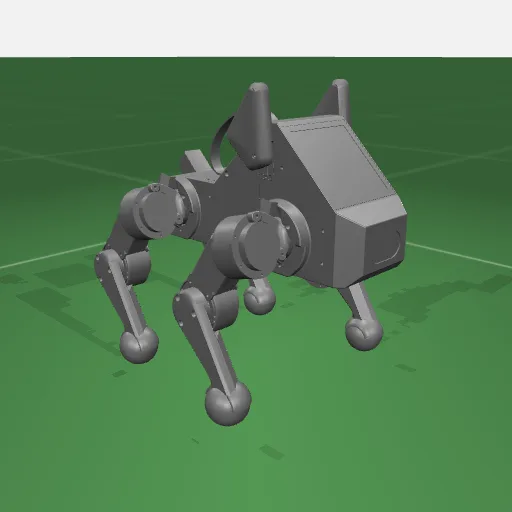 Pupper V3
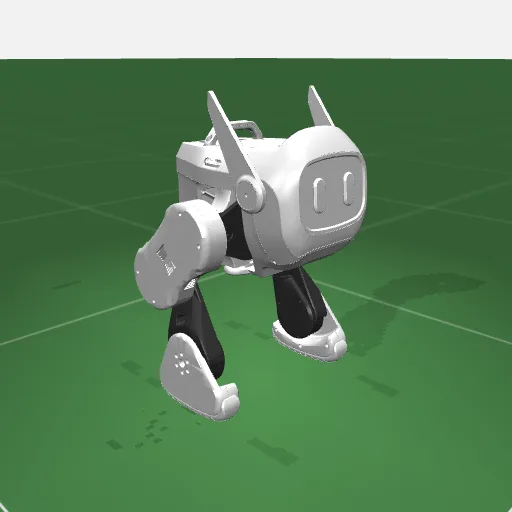 Qmini
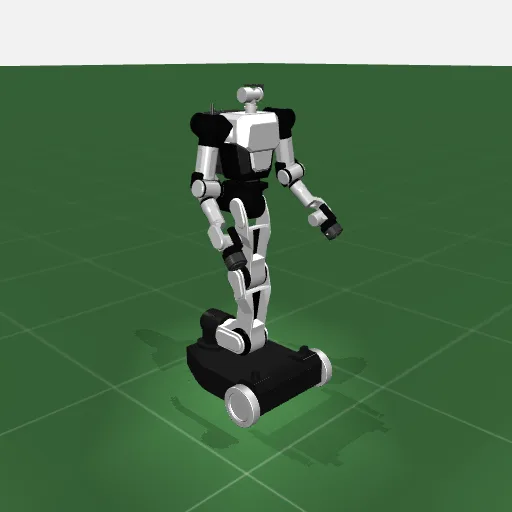 Rainbow Rby1
 Rainbow Robotics RBQ10
 Raph Rover
 Reachy
 RealMan RealBot-01
 Rethink Sawyer
 Rh5
 Rhea
 Ridgeback Franka
 Ridgeback Ur5
 Robonaut 2
 Roboparty Atom01
 Robot Soccer Kit
 Robotera Xbot
 Robotis Ffw
 ROBOTIS K1
 ROBOTIS OMY-3M
 Robotis Op3
 ROBOTIS OpenMANIPULATOR-X
 ROBOTIS THORMANG3
 ROBROS IGRIS-C
 Romeo
 Sanctuary Phoenix
 Sanity
 Sanity CTBR
 Seeed Rebot Devarm
 seriBot
 SH Humanoid
 Shelfy
 Sigmaban
 Silver Badger
 Skydio X2
 Snake
 So101
 Solo12
 SpaceR Floating Platform
 Spot
 Spot Mini
 Spot With Arm
 Sprite
 Spryped
 Stanford Tidybot
 Star1
 Starling 2 CTBR
 Starling 2 Max
 Starling 2 Max CTBR
 Starling 2 Max CTBR Gripper
 SUSTAINA-OP
 Talos
 Techman Tm12
 Terra++ Lite 6
 TerraSentia
 Tiago
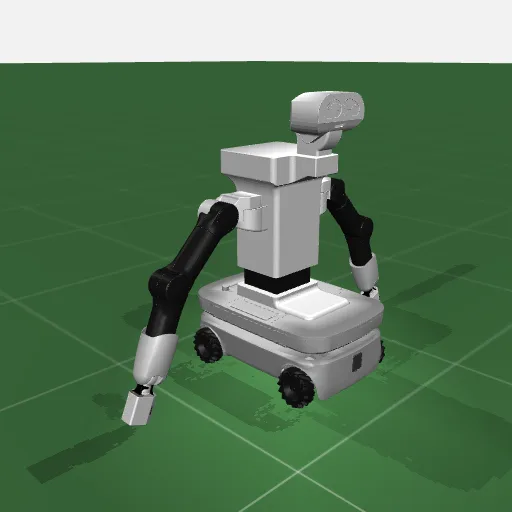 Tiago Dual
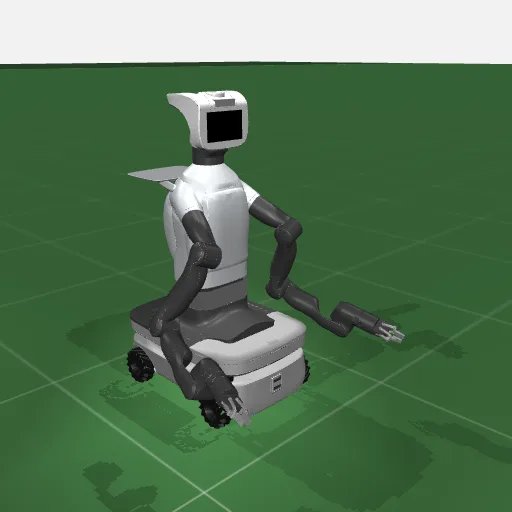 TIAGo Pro
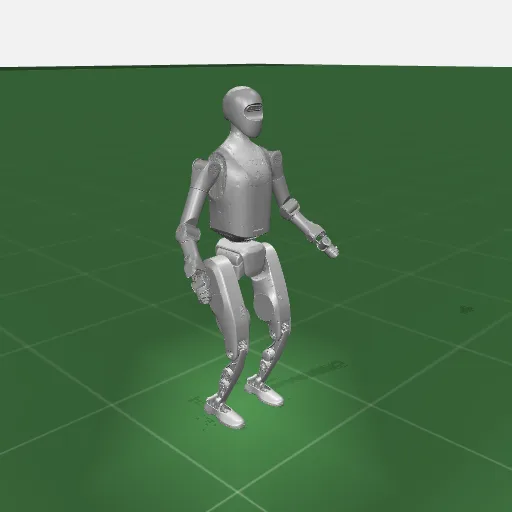 TianGong 2.0 Pro
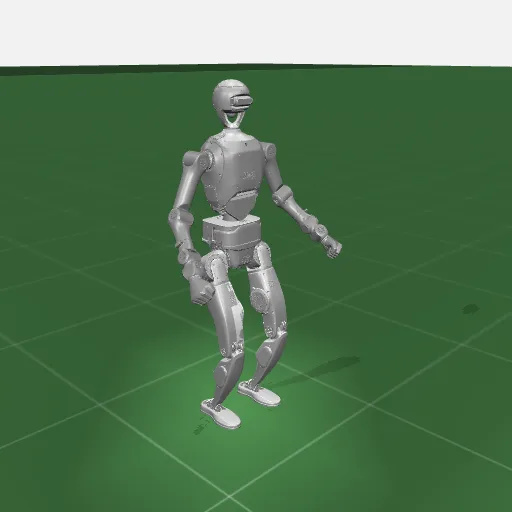 TianGong 3
 TianGong Station
 TianYi 2.0
 Tidybot2
 TienKung Lite
 TienKung Pro
 Toddlerbot
 Tokyo Robotics Torobo2
 Tom Hexapod
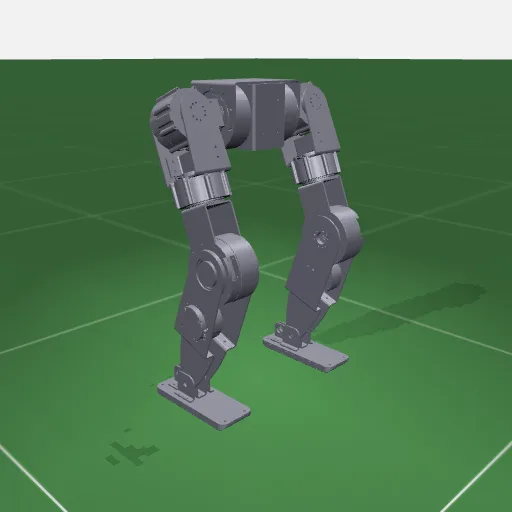 Triton Humanoid
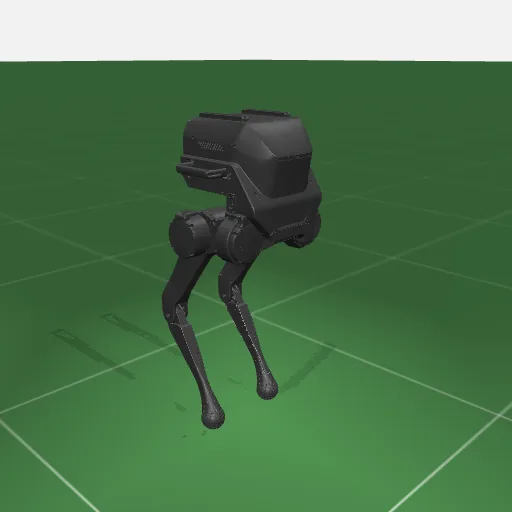 Tron1
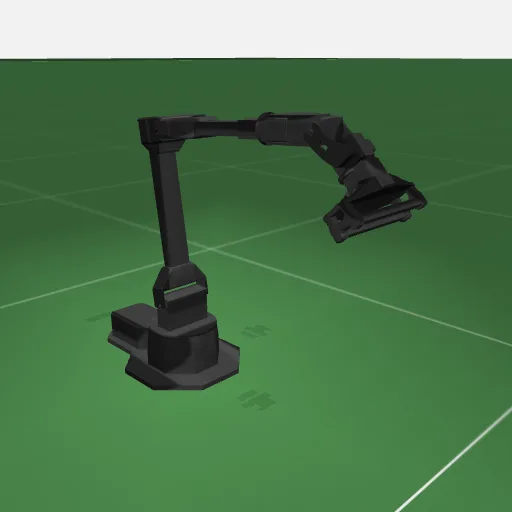 Trossen Vx300s
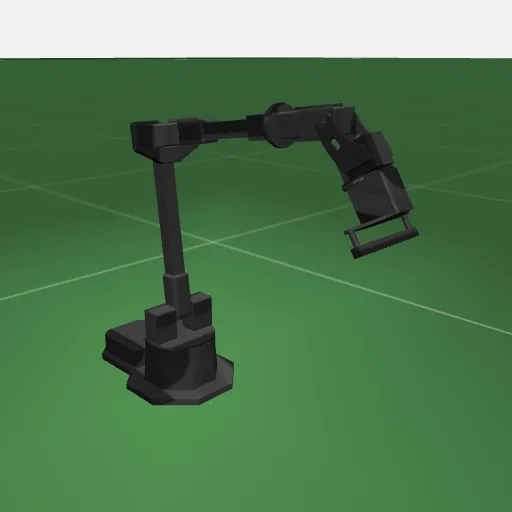 Trossen Wx250s
 Trossen Wxai Biarm
 Trossen Wxai Follower
 Trs So Arm100
 TurtleBot 4
 Turtlebot3
 UBTECH Walker S2
 Ufactory Lite6
 Ufactory Xarm7
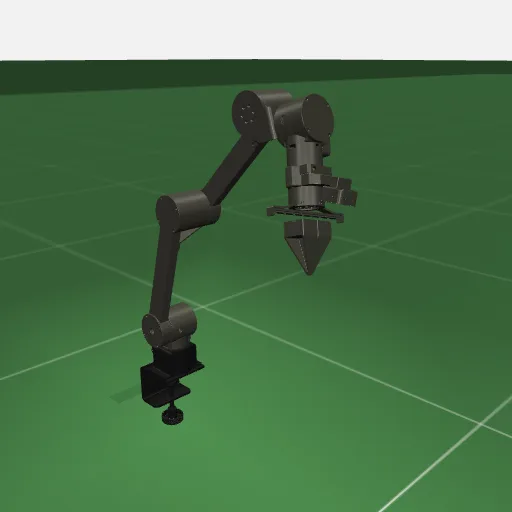 Ulixarm
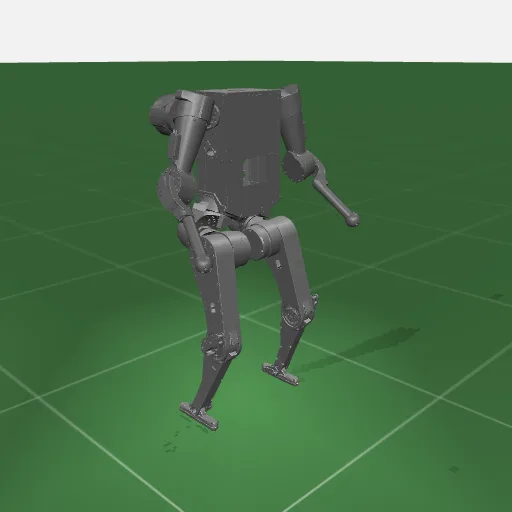 UMass Humanoid
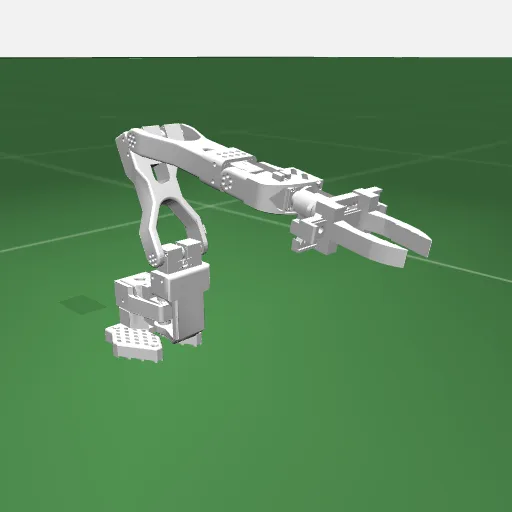 Uniarm L1
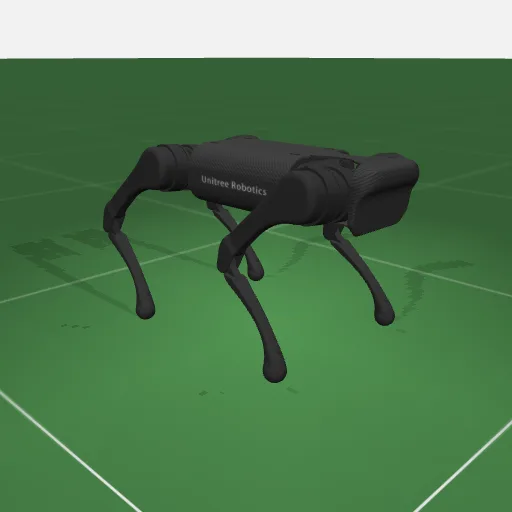 Unitree A1
 Unitree A2
 Unitree Aliengo
 Unitree AS2
 Unitree AS2-W
 Unitree B1
 Unitree B2
 Unitree B2w
 Unitree G1
 Unitree G1-D
 Unitree Go1
 Unitree Go2
 Unitree Go2W
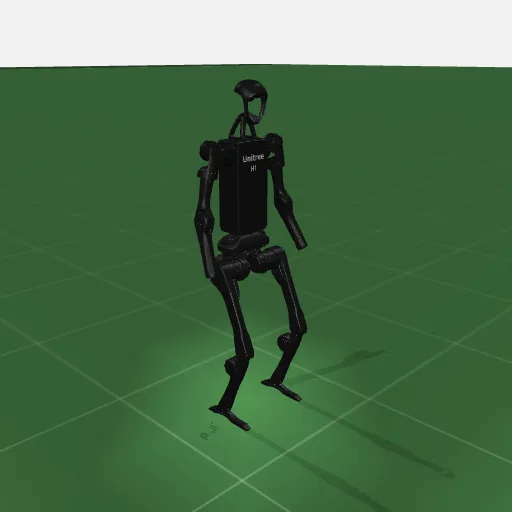 Unitree H1
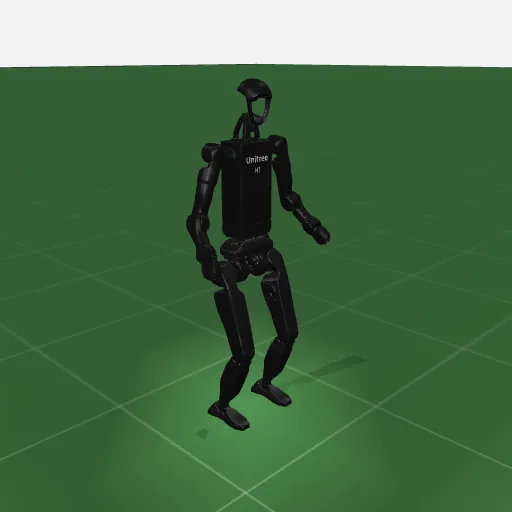 Unitree H1-2
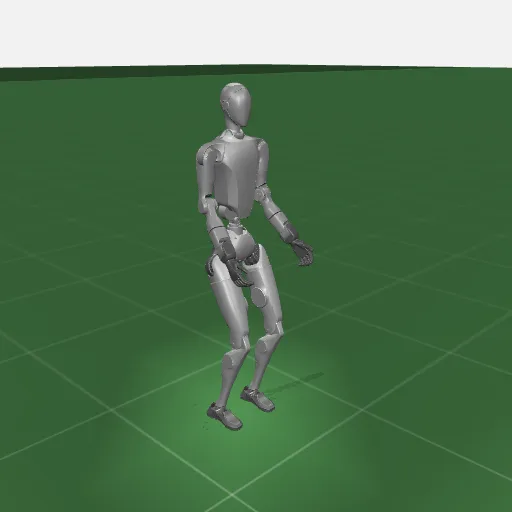 Unitree H2
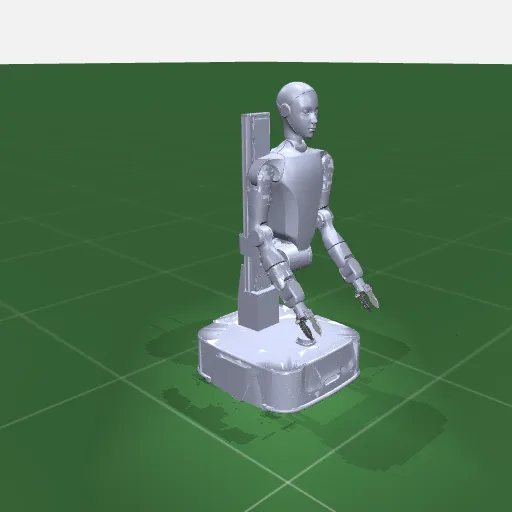 Unitree H2-D
 Unitree R1
 Unitree R1-D
 Unitree Z1
 Upkie
 UR3E
 UR5E
 UR10E
 UR16E
 UR20
 UR30
 Valkyrie
 VinRobotics VR M3.1
 WALK-MAN
 X-Humanoid Servo Arm
 XGO Lite 3
 XGO Mini 2S
 XGO Mini 2SW
 XGO-Duck
 Xiaopeng Px5
 Yumi
 Zbot
 Zhinao L4w4
 Zsibot Zsl1
 Zsibot Zsl1w
No matching robots.
Contribute to γ0
Help us build a foundation motion policy that transfers across robots on the ground and in the air, with wheels, legs or rotors, supported by the largest open-source robot collection.
We have two ways for you to get involved!
Contact us at contribute@gamma-zero.com until .
We’ll publish the policy and robot collection shortly after.
A.
Contribute your robot model
Share a valid URDF for a real-world robot that we can simulate with MuJoCo, including meshes, inertial parameters, joint limits, and actuator torque and velocity limits. Accepted models will become part of the open-source collection, and contributors will be cited or acknowledged. We welcome legged robots, wheeled robots, manipulators and drones. Standalone robot hands are outside the scope of this collection.
B.
Train and deploy with us
Collaborate with us to extend the training pipeline and deploy γ₀ on new hardware. Contributions spanning both training and real-world deployment may qualify for authorship.
Our growing team
Nico Bohlinger Co-lead
TU Darmstadt
Bo Ai Co-lead
Stanford University
Dichen Li
UC San Diego
Tongzhou Mu
Rhoda AI
Sophie Lueth
TU Darmstadt
Nicolas Hahn
TU Darmstadt
John Tucker
Stanford University
Chenhao Li
ETH Zurich
Yutong Wang
Carnegie Mellon University
Ismail Geles
University of Zurich
Tongxuan Tian
University of Southern California
Hongyi Jing
University of Southern California
Jiankai Sun
Stanford University
Tan-Dzung Do
VinRobotics
Lu Liu
LimX Dynamics
Francisco Affonso
University of Illinois Urbana-Champaign
Jose Cuaran
University of Illinois Urbana-Champaign
Welf Rehberg
NTNU
Mohit Singh
NTNU
Grzegorz Malczyk
NTNU
Calum Arnott
University of Edinburgh · Heriot-Watt
Sümer Tunçay
Heriot-Watt University
Peter Heedo Woo
University of Cambridge
Harold Ruiter
University of Amsterdam · whIRLwind
Nikolas Tsagkas
University of Amsterdam
Muslim Alaran
Montanuniversität Leoben
Hesam Mojtahedi
UC San Diego
Matteo El Hariry
University of Luxembourg
Ricard Marsal i Castan
University of Luxembourg
Hojune Kim
Stanford University
Williard Joshua Jose
UMass Amherst
Li Chen
UMass Amherst
Shangqun (Simon) Yu
UMass Amherst
Robert Antaluca
Inria · HUCEBOT
Dionis Totsila
Inria · HUCEBOT
Phani-Teja Singamaneni
Inria · HUCEBOT
Yixuan Huang
Princeton University
Sabrina Liu
Princeton University
Robot model contributors
Ulises Campodónico
Universidad de Chile · KTH
KiLTRO
Aleksandr Semochkin
Green robot
Green
Stefano Berti
Istituto Italiano di Tecnologia
R1 Mk3
Minsu Kim
ROBROS
IGRIS-C
Ola Ghattas
Hello Robot
Stretch 4
Joshua Jerin
University of Cincinnati
Kural
Jan Schneider
MPI for Intelligent Systems
PAMY2
Giulio Turrisi
Istituto Italiano di Tecnologia
HyQReal2
Parth Trivedi
UC San Diego · Triton Droids
Triton Droids humanoid
Advisors
Jan Peters
TU Darmstadt
Chelsea Finn
Stanford University
Hao Su
Sudo AI GmbH
Henrik I. Christensen
UC San Diego
Georgia Chalvatzaki
TU Darmstadt
Mac Schwager
Stanford University
Marco Hutter
ETH Zurich
Guanya Shi
Carnegie Mellon University
Davide Scaramuzza
University of Zurich
Yue Wang
University of Southern California
An Thai Le
VinUniversity · VinRobotics
Konstantinos Alexis
NTNU
Ignacio Carlucho
Heriot-Watt University
Michael Mistry
University of Edinburgh
Matteo Saveriano
University of Trento
Miguel Olivares-Mendez
University of Luxembourg
Serena Ivaldi
Inria · HUCEBOT
Elmar Rückert
Montanuniversität Leoben
Girish Chowdhary
University of Illinois Urbana-Champaign
Amanda Prorok
University of Cambridge
Hao Zhang
UMass Amherst
Donghyun Kim
UMass Amherst
Arnoud Visser
University of Amsterdam
Stratis Gavves
University of Amsterdam
Tom Silver
Princeton University
Jan Emrich
Cerepal.AI